
SOLUTIONS & ROADMAP
The right technology
for the surgical task.
One intelligence platform, expressed through a modular family of vision, navigation and robotic technologies. Designed for different procedures, preferences and care settings.
REDEFINE SURGERY / SOLUTIONS & ROADMAP
A CONFIGURABLE PLATFORM
One vision system.
Your way to operate.
Explore the same shark-fin vision platform on its own, with an articulated robotic arm, alongside compact micro-robotics, or with handheld instruments.
Configuration illustrations show our development direction. Hardware, interfaces and workflows are defined for each application.
THE DEVELOPMENT PORTFOLIO
Start with the workflow.
Choose the form factor.
PERCEPTION + NAVIGATION
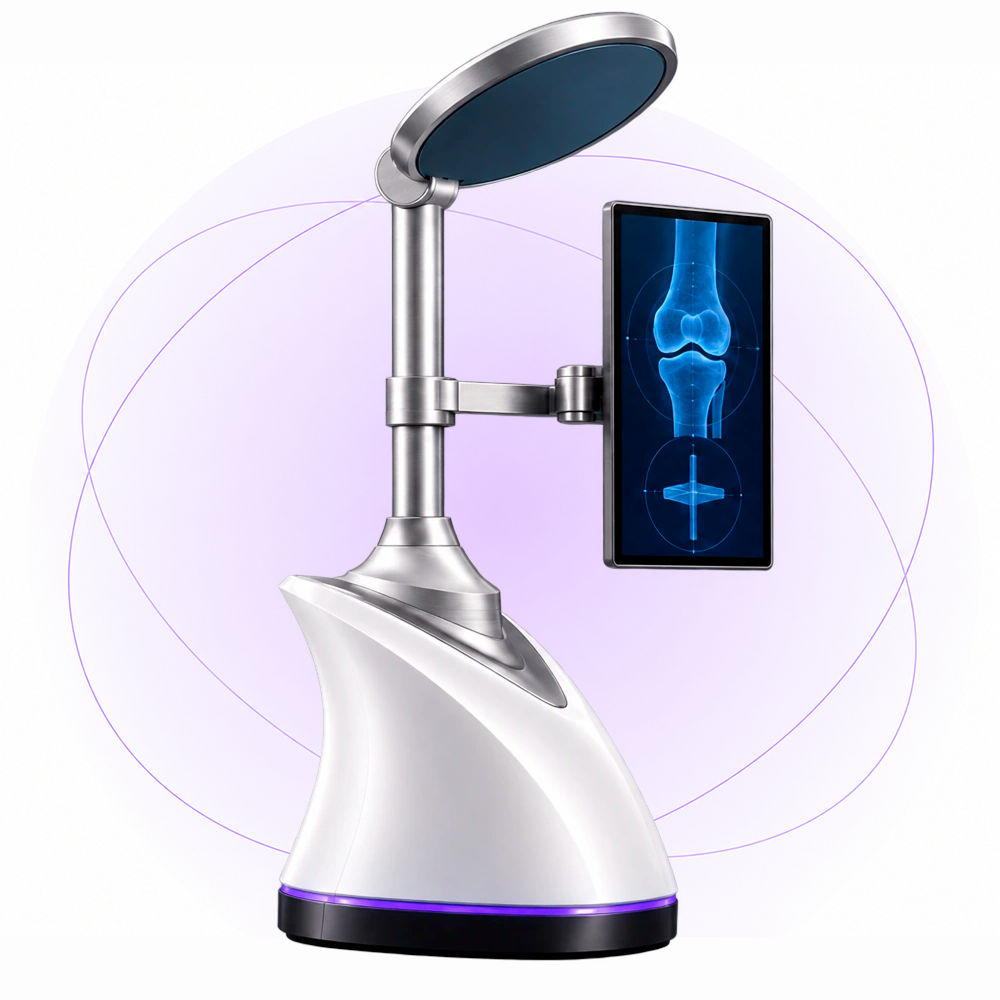
MEG Vision System
The spatial foundation of the platform. Computer vision is being developed to recognize exposed anatomy, align it with a surgical plan and track the procedure without conventional tracking arrays.
Markerless anatomy registration
Three-dimensional surgical perception
Navigation and data capture foundation
SURGEON-CONTROLLED EXECUTION
Explore the technologies that can become part of a partner solution. These are development programs, not commercially available products.
COMPACT ROBOTIC GUIDANCE
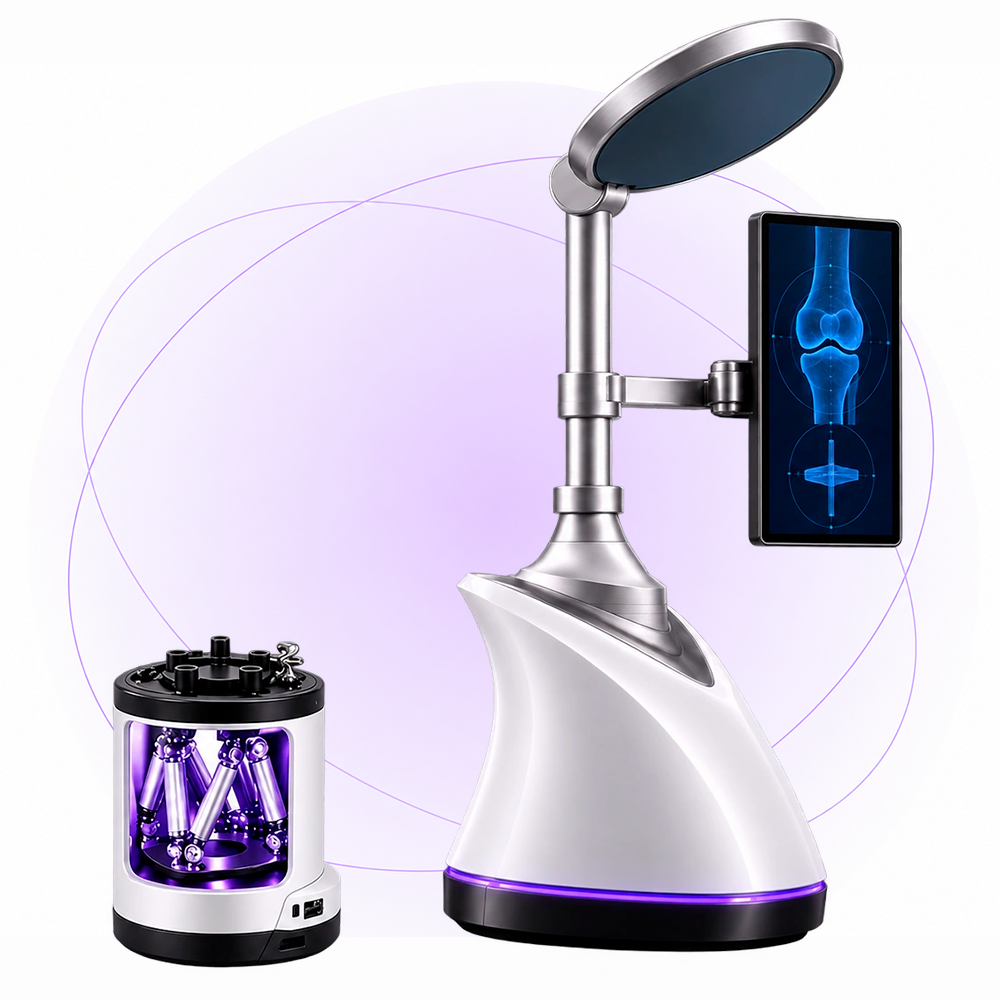
MEG Micro-Robot
A compact precision platform designed to configure adjustable surgical guides and bring robotic positioning into familiar surgical workflows.
Adjustable patient-specific guidance
Compact approach to robotic positioning
Shared intelligence with the vision platform
GUIDED HANDHELD TOOLS
ROBOTIC COLLABORATION
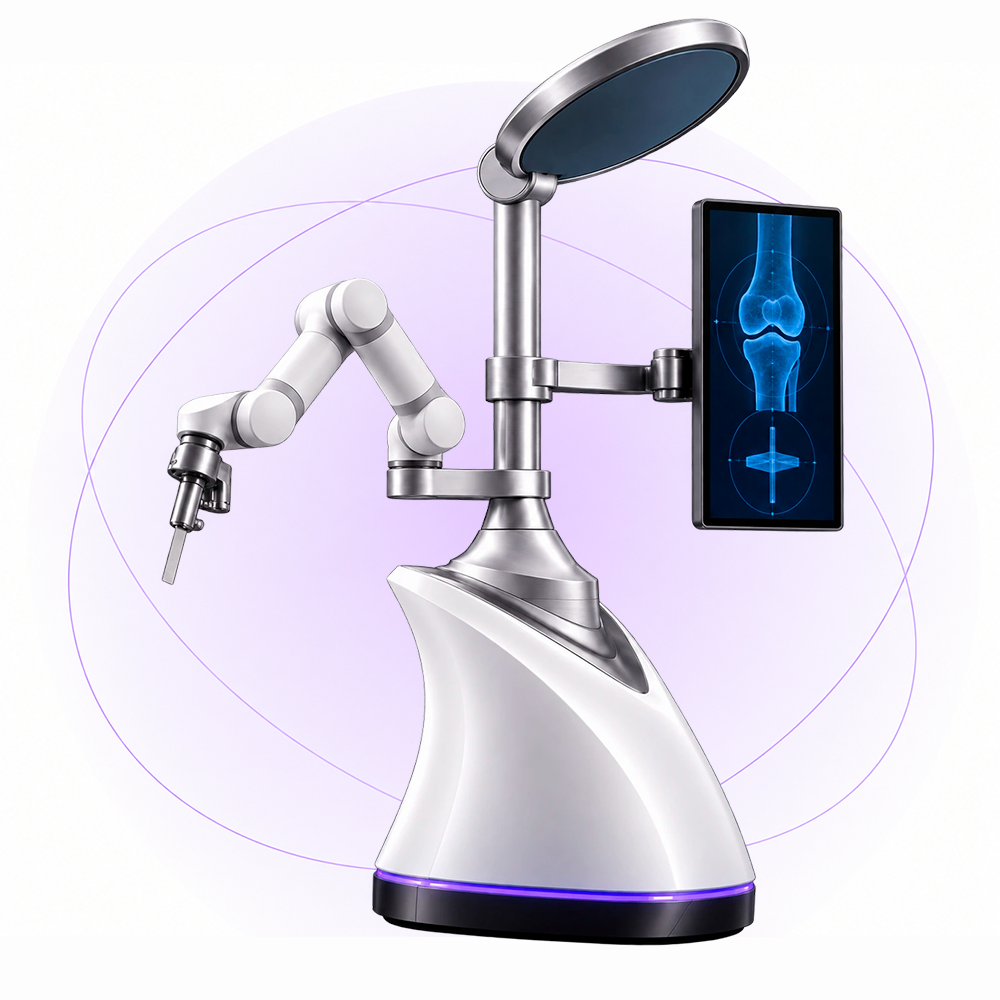
An adaptable robotic architecture designed to share the same perception and intelligence foundation, with end effectors matched to the procedure.
Procedure-specific end effectors
Integration with surgical navigation
Configurable partner applications
Robotic Arm Systems
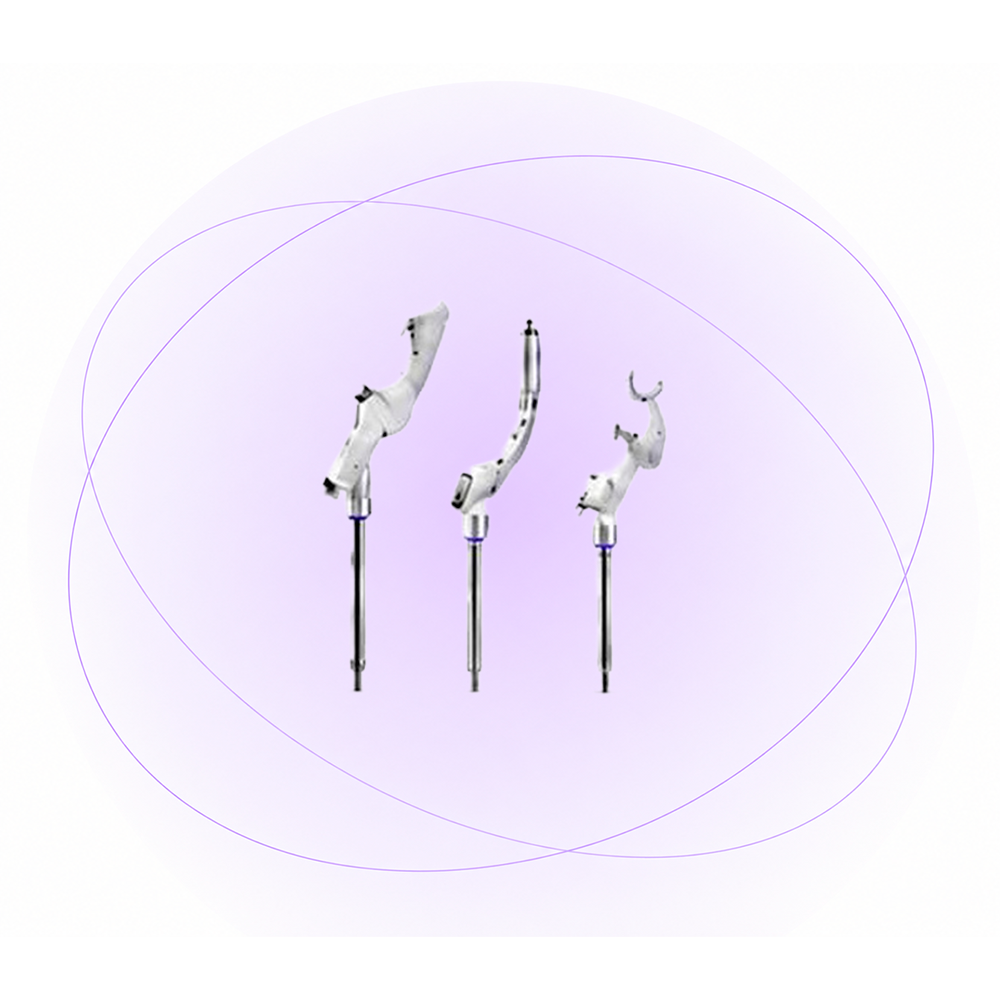
Navigated Instruments
Familiar instruments connected to spatial guidance. The goal is to help surgeons carry a plan into the procedure while retaining hands-on control.
Guidance within familiar techniques
Disposable or reusable instrument concepts
Designed for partner-specific workflows
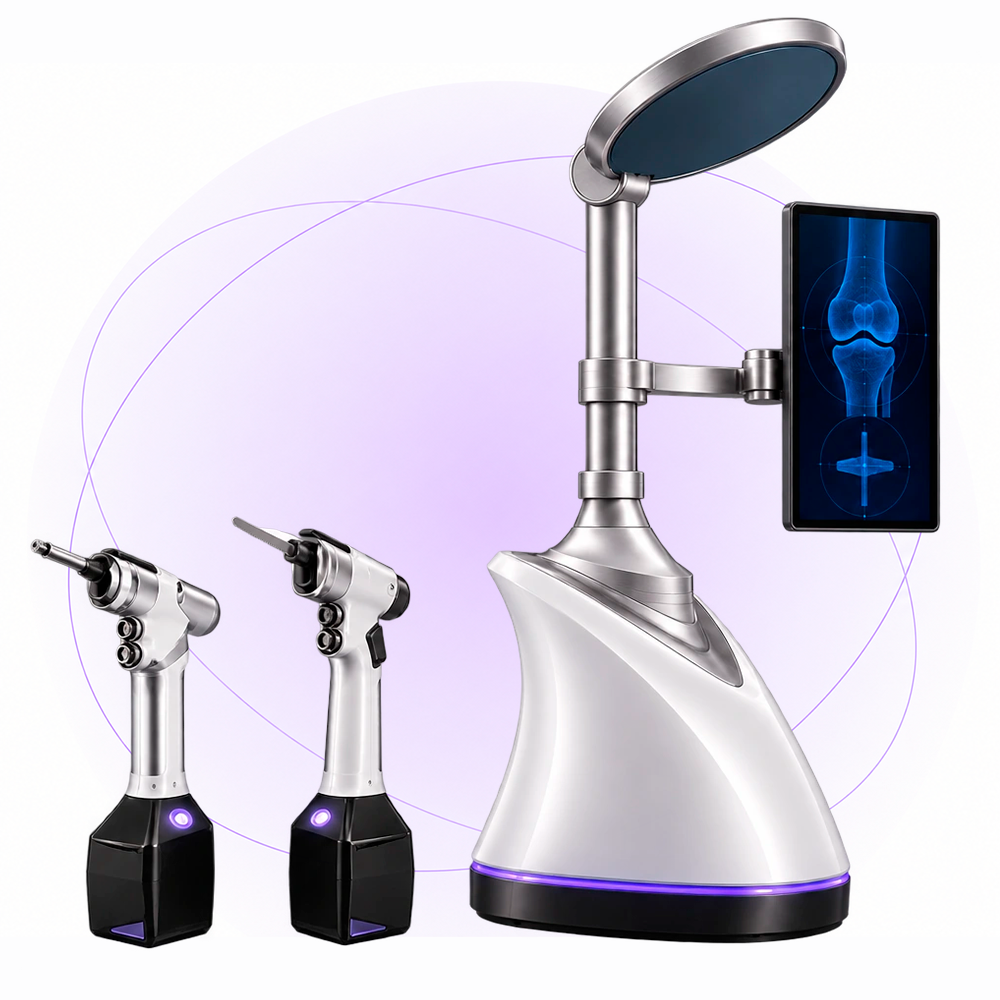
Handheld Surgical Tools
A development direction for handheld instrumentation connected to navigated guidance, with axial reaming and saw-based tool concepts.
Real-time orientation guidance
Angular adjustment concept
Portable handheld form factor
PARTNER-SPECIFIC DEVELOPMENT
Explore how the platform could support your anatomy, surgical technique, instruments or robotic architecture.
Your next solution could start here.
A CONNECTED ROADMAP
Build once.
Enable more.
Establish the spatial foundation
Develop vision-based registration, anatomy understanding and navigation as reusable capabilities across the product family.
Connect guidance to tools
Integrate navigated instruments, adjustable guides and compact robotic positioning into specific surgical workflows.
Expand collaborative intelligence
Develop the Surgical Mentor and support additional physical interfaces as data, validation and clinical requirements evolve.
DEVELOPMENT WITH CLARITY
Each application earns
its own evidence.
Accuracy, workflow performance and clinical suitability depend on the anatomy, configuration and intended use. These must be established through the relevant validation program and regulatory pathway.
-
The architecture is designed for modular integration. The right starting point may be perception, navigation, guidance or a physical tool. Technical scope and interfaces are defined in a joint feasibility process.
-
The platform is being developed as an open architecture that can be configured for partner implants and workflows. Compatibility and intended use must be established for each integration.
-
Our design direction emphasizes portable, efficient technology adaptable to different care settings, including ambulatory surgery centers. Each specific deployment remains subject to validation and the applicable requirements.
-
Contact the team with your specialty or application. We can discuss the appropriate demonstration, development status and validation information for your interests.